|
| Figure 1, Ping Pong Robot |
Member Names (with emails)
KoTung Lin (kevinlin [at] umich.edu)
Daniel Cheng (udx [at] umich.edu)
Brief Project Description
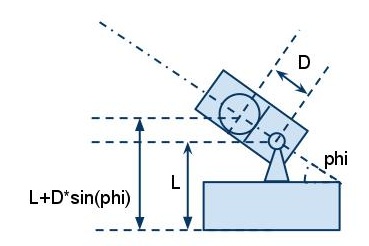
Our goal is to implement the the inverse kinematic and forward kinematic for the ping pong ball robot and make the ping pong reaching the entire workspace. We will attempt to achieve the following: ground target aiming, trajectory planning for singularity prevention and integrate with the GUI operation panel for with trajectory prediction.
Objectives
- Forward kinematic
- Inverse kinematic
- Singularity prevention
- Graphic User Interface
- Trajectory prediction and projection to the alternative camera view point